Stanford Pupper v3
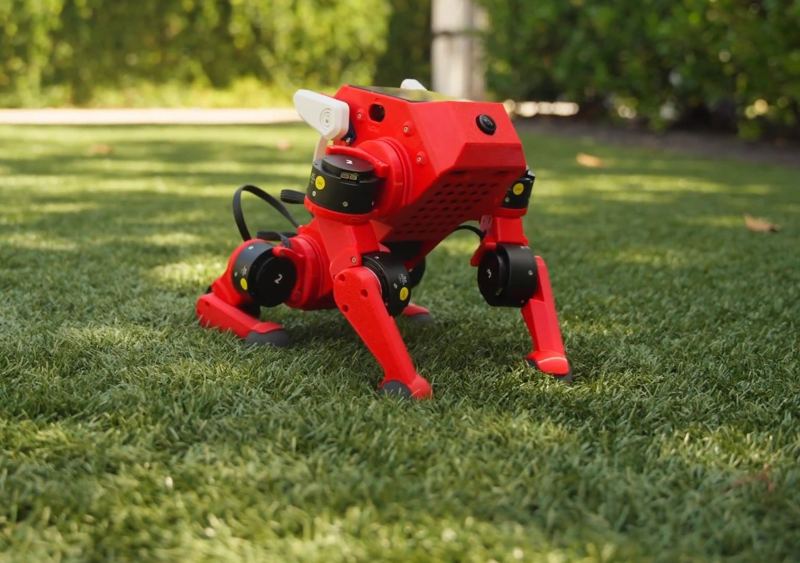
Open-source quadruped for teaching robotics and AI, driven by twelve brushless actuators and a Raspberry Pi 5, with locomotion policies trained by reinforcement learning in simulation. It weighs about 3 kg.
Stanford Student Robotics · LeggedReport an error
Models that run on it0
No models tracked yet.